All projects
Technical projects across control engineering, embedded systems, robotics, computer vision, and AI.
Featured projects
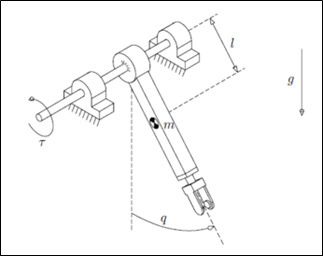
PMSM vector control design
Simulink study of one joint of a robot arm driven by a permanent-magnet synchronous motor: nonlinear and linearised models, a cascaded vector controller with a torque modulator and an observer, checks against the real component limits, non-ideal sensors and inverter, and a discretised controller programmed in MATLAB.
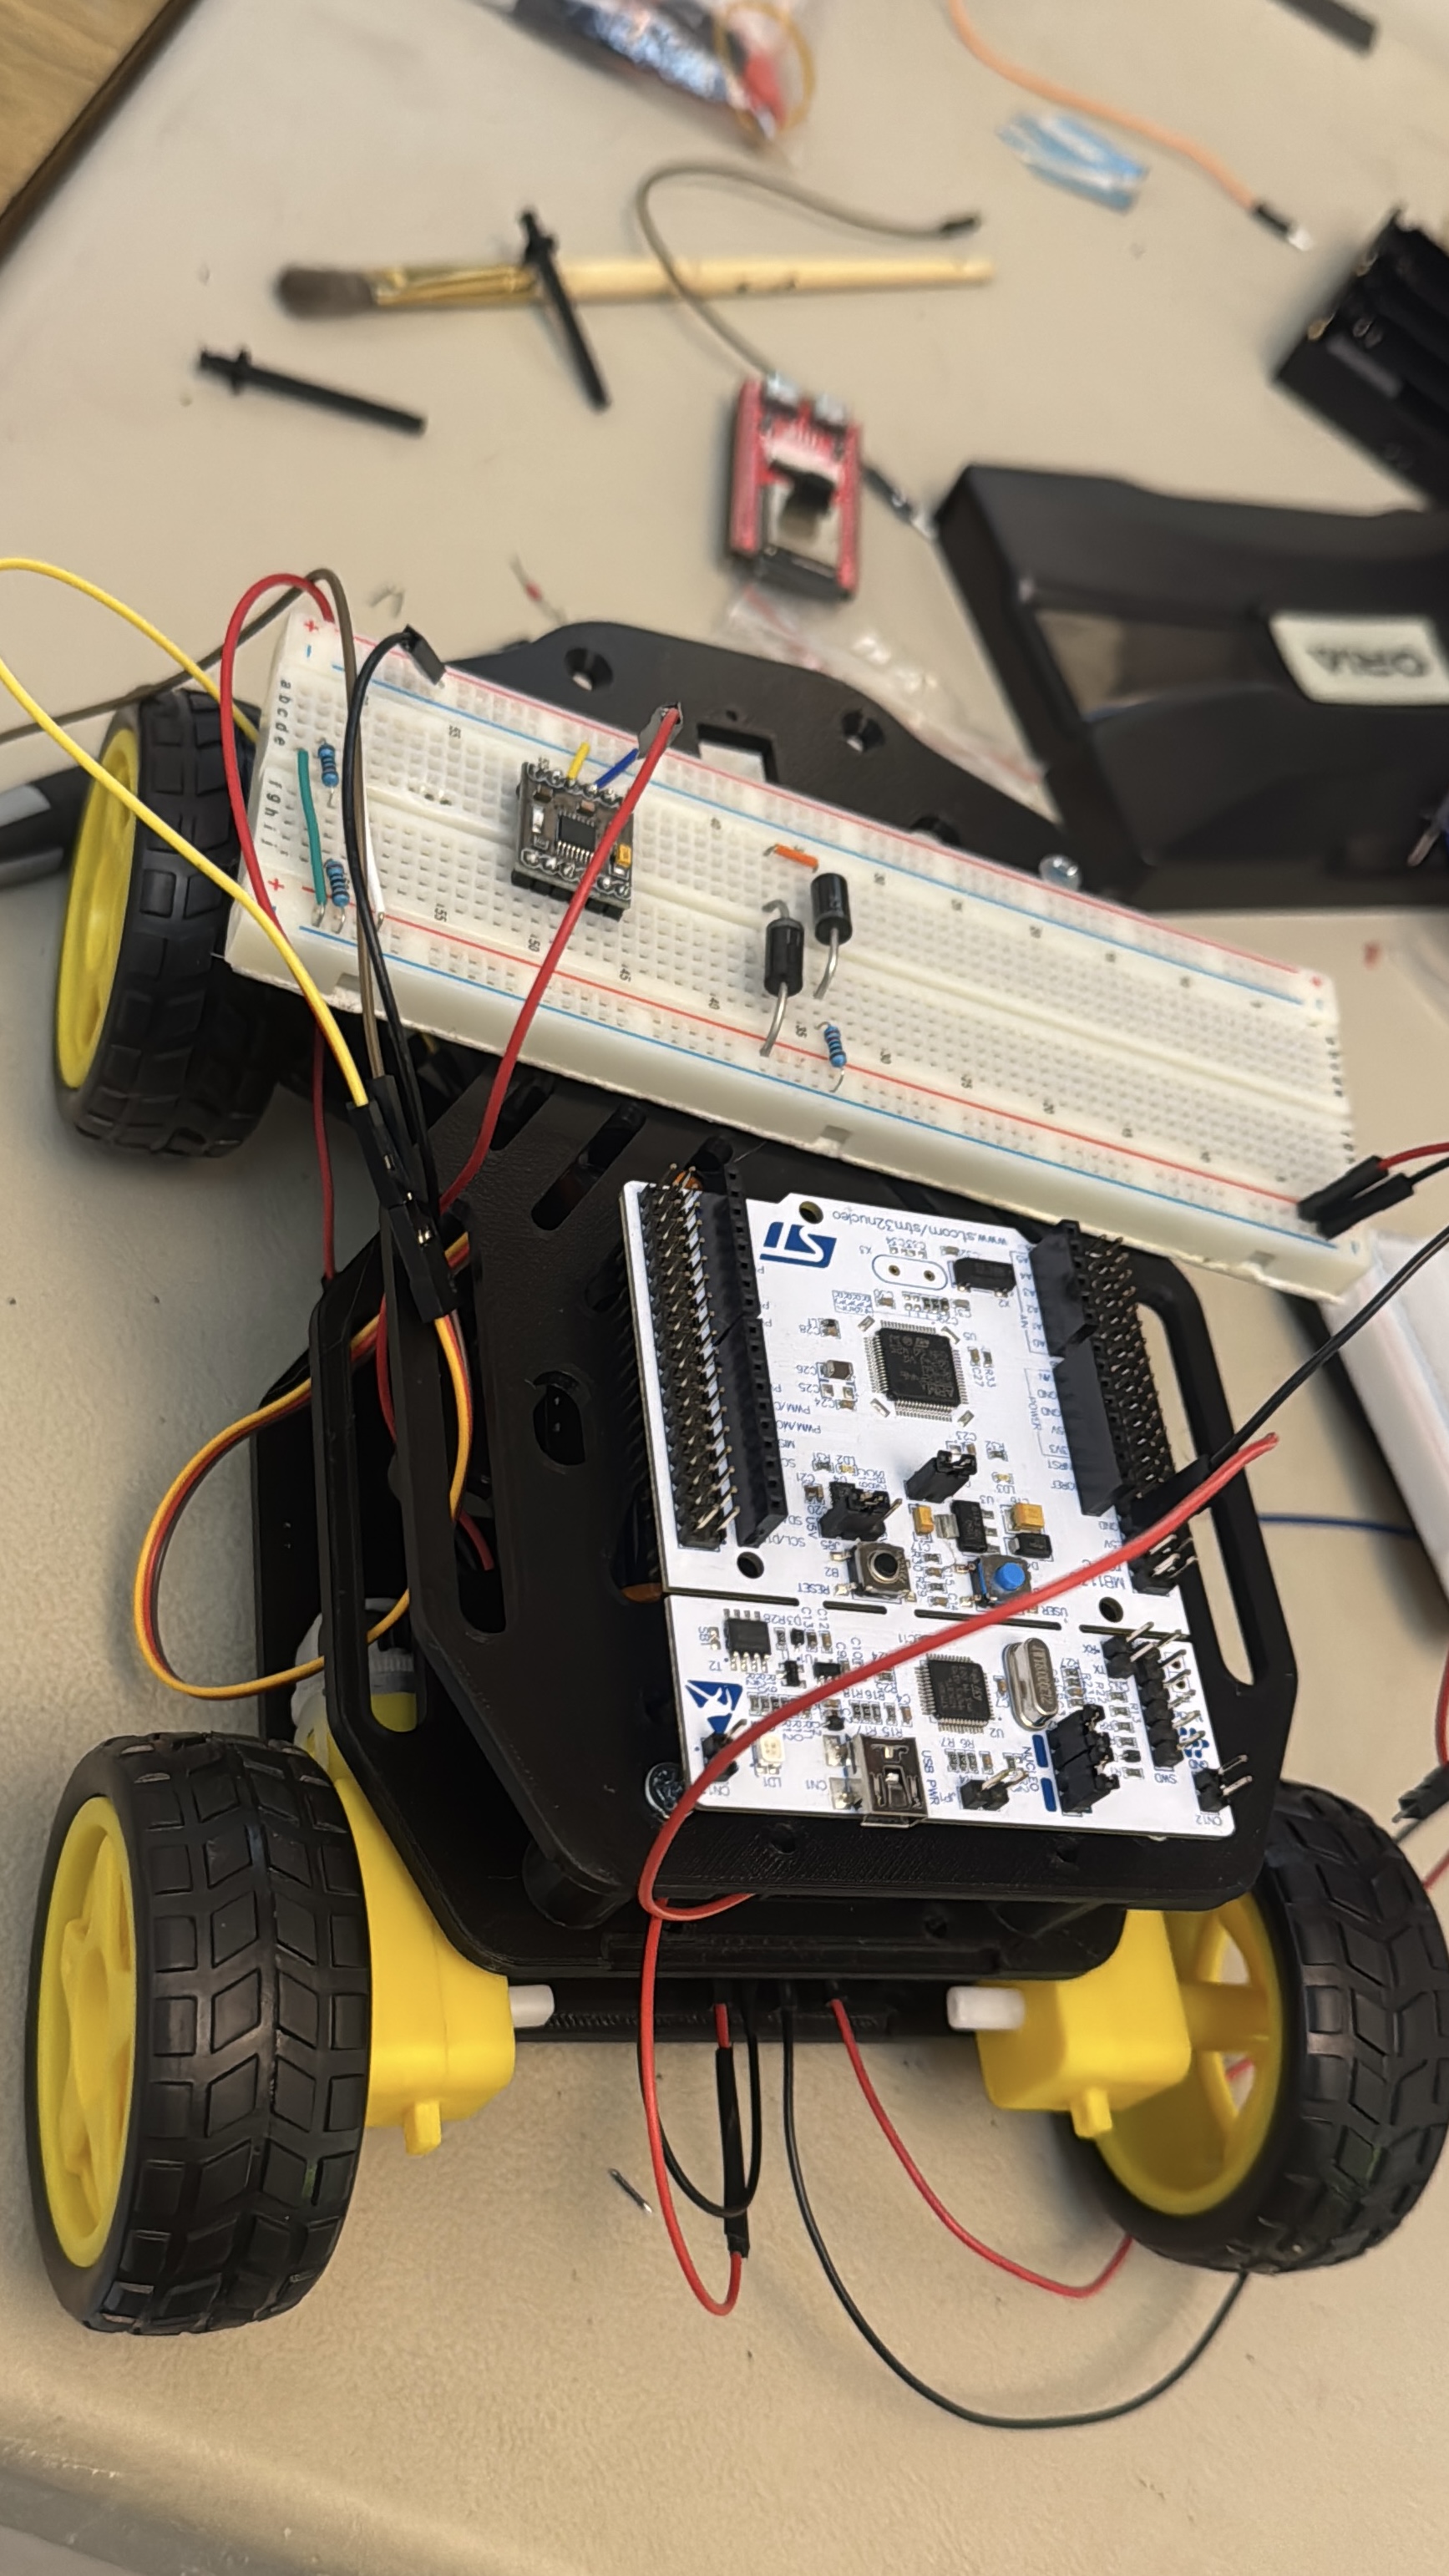
Real-time Wi-Fi mobile robot
Remote-controlled car with a two-board architecture: an ESP32-S3 creates the Wi-Fi network and forwards TCP commands over UART to an STM32 running FreeRTOS, which drives the motors and the steering servo and stops on obstacles. Operated from a PyQt5 interface.
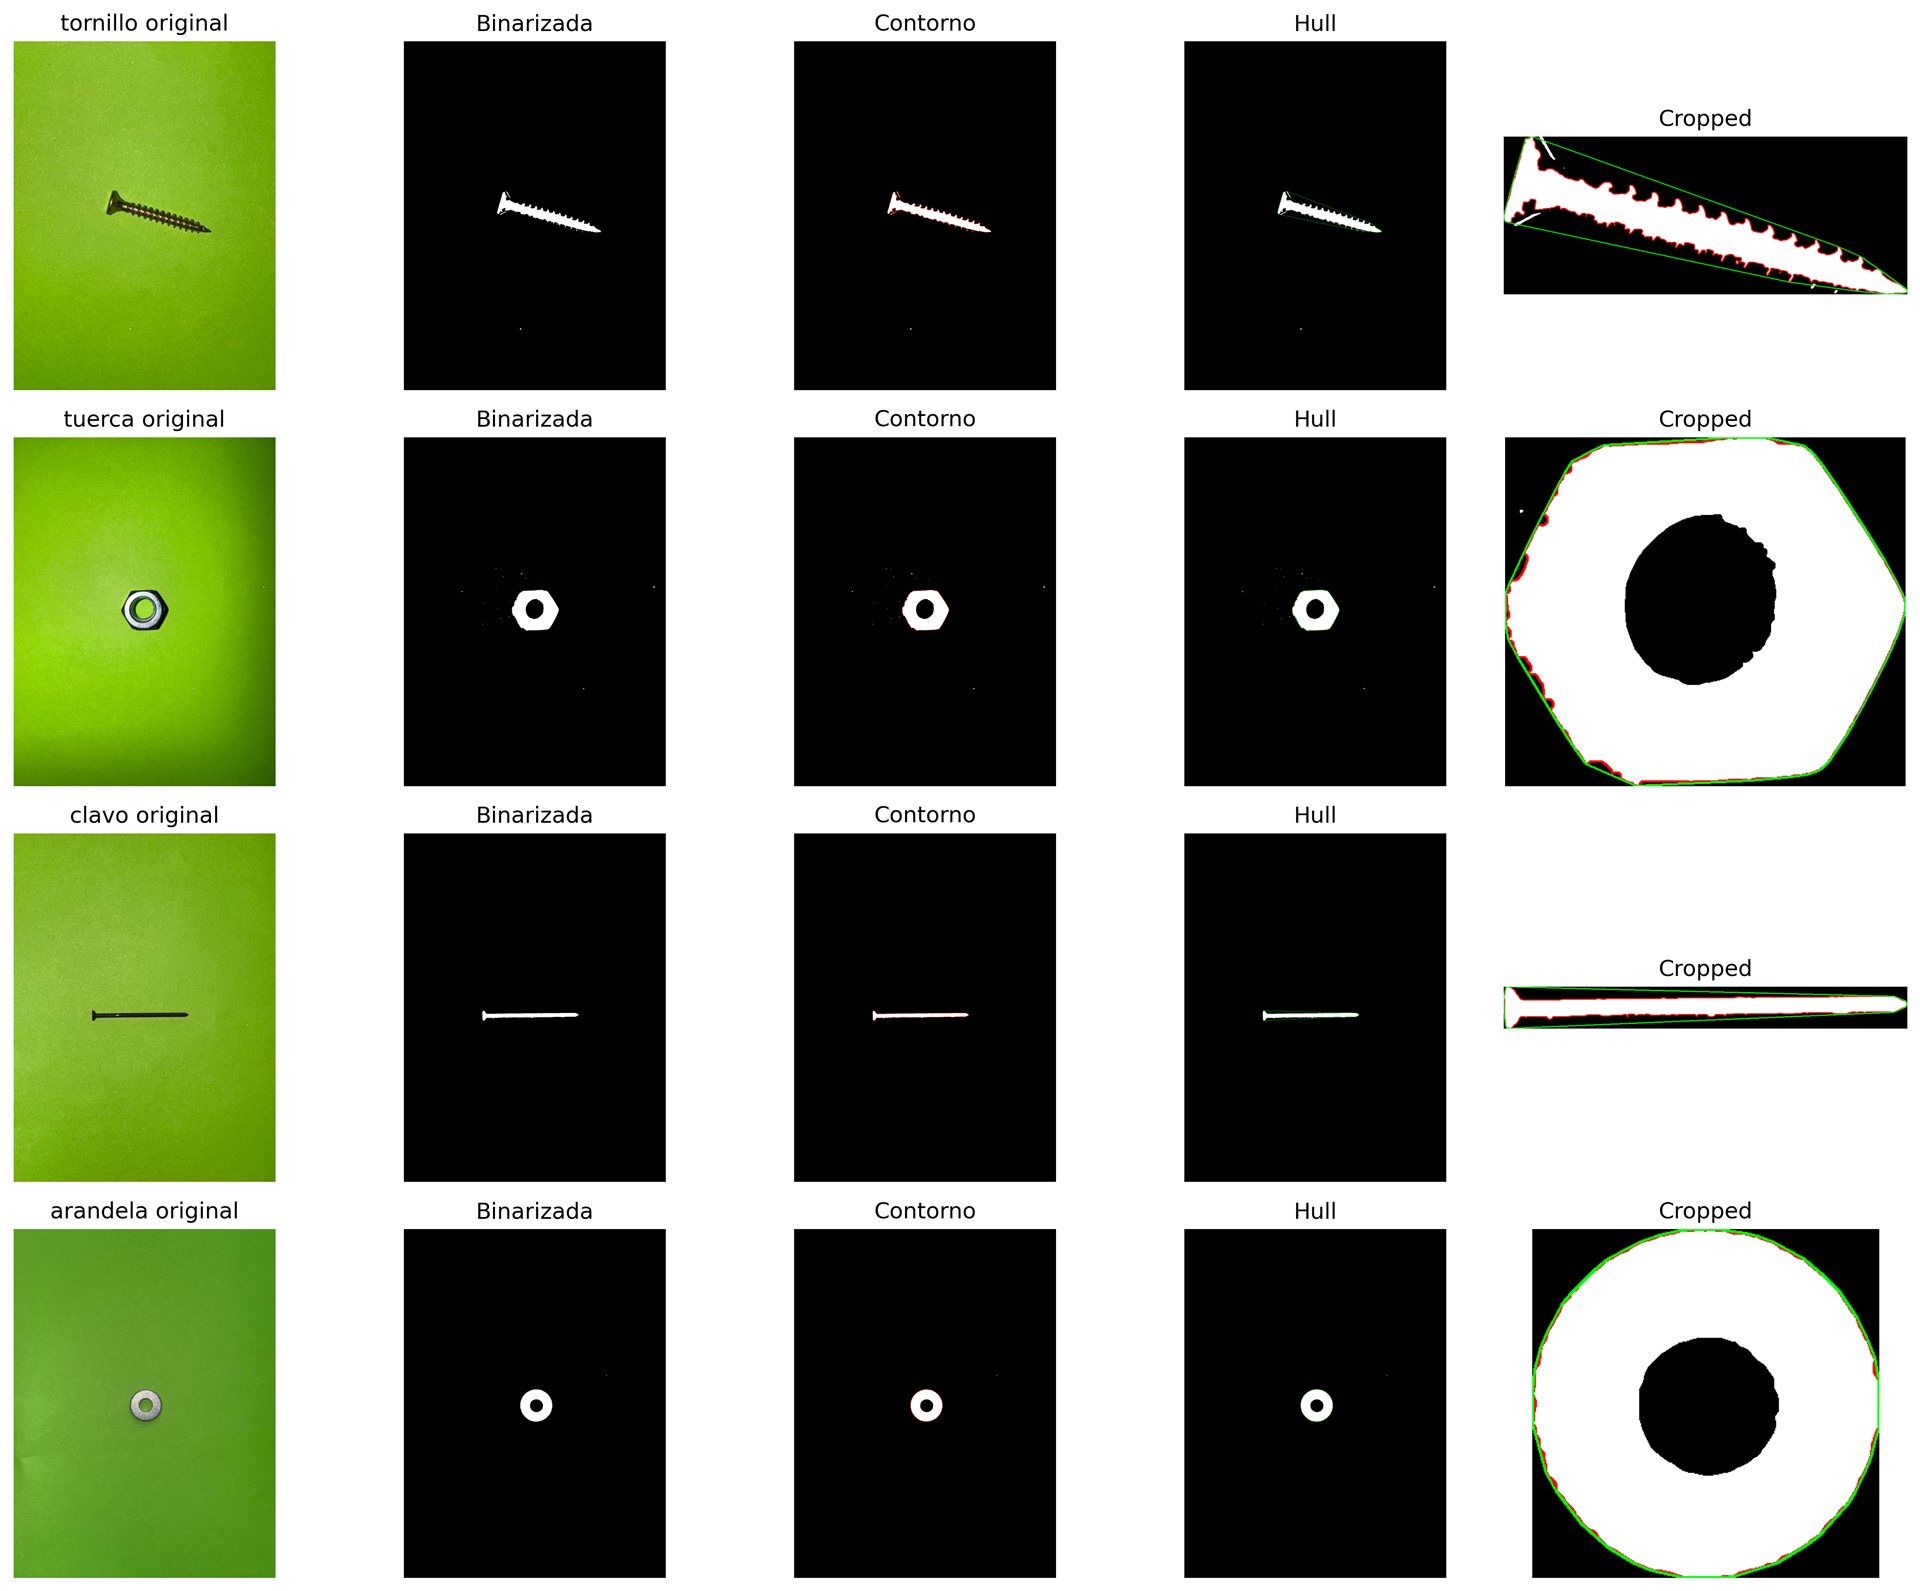
Autonomous intelligent agent simulation
Three-stage Python agent for a university AI course: classify industrial parts from phone photos (KNN and K-Means written from scratch), plan how to re-stack them with STRIPS/PDDL, and cross a random maze with A*.
More projects
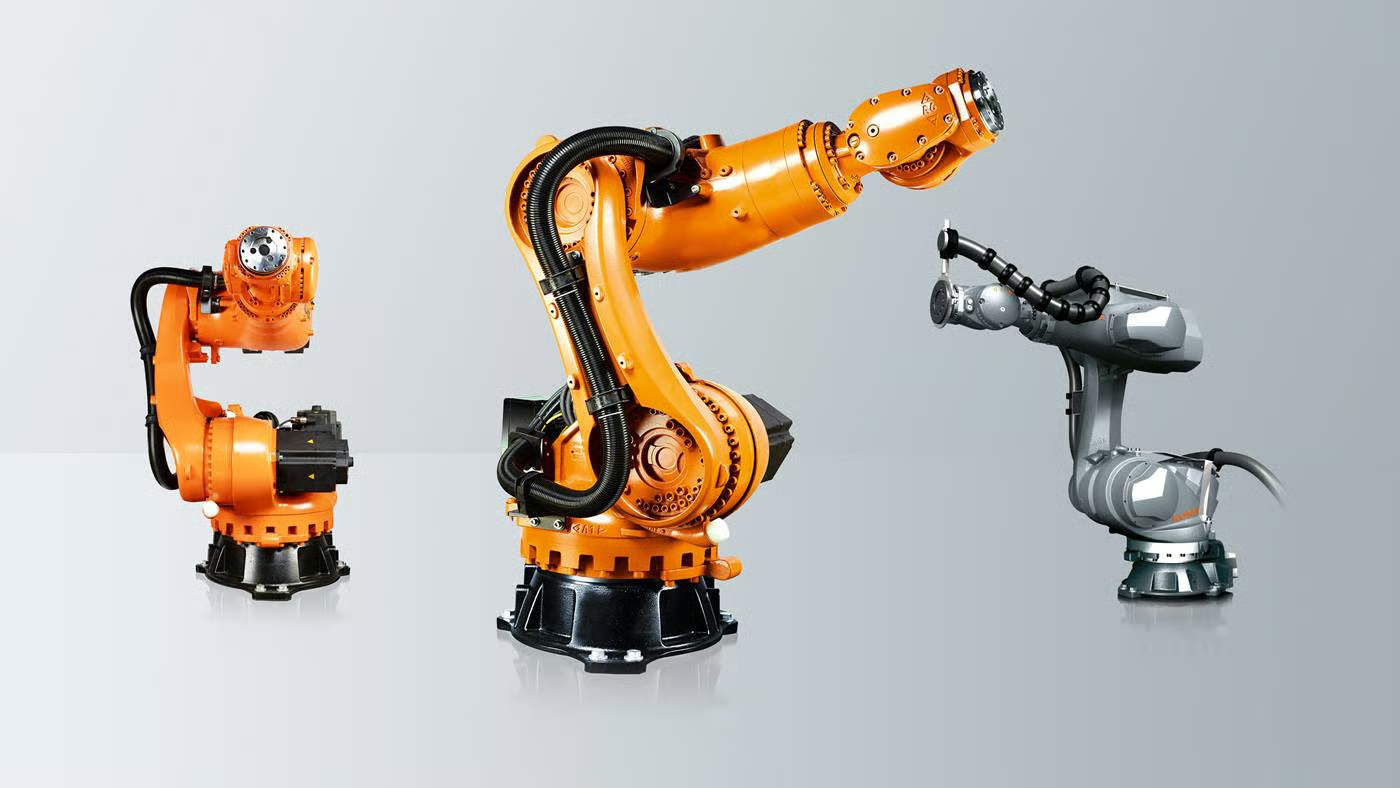
6-DOF serial robot kinematics
MATLAB kinematic study of three KUKA KR 120 robots that pass a cast part through two forging presses to a conveyor: Denavit–Hartenberg model, Pieper inverse kinematics, a numerical search for singularities and mixed Cartesian and joint trajectories.
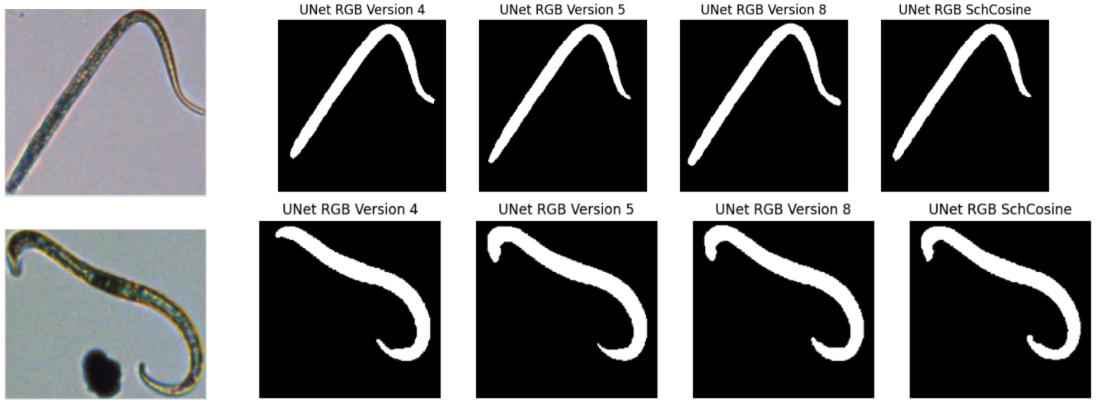
Automated morphometry with AI and image processing
My module of the BlueRevolution project (ENIB, Lab-STICC, Ifremer): masks made with SAM, synthetic labelled images and a U-Net that separate nematodes and copepods from debris in microscope photos, feeding the team's morphometry pipeline.

Digital audio synthesizer (subtractive)
Monophonic subtractive synthesizer on an STM32F746 Discovery: wavetable oscillator, state-variable filter, ADSR envelope and LFO computed at 44.1 kHz inside the codec interrupt and played from a USB MIDI keyboard.